AI Enthusiastic & Robotics Engineer
Building Intelligent
Systems That |
MSc Robotics Graduate specialising in Intelligence systems, HRI, IoT, ROS, Generative AI, LLM safety, and embodied intelligence. Bridging the gap between powerful AI models and safe real-world deployment.
Quick Summary
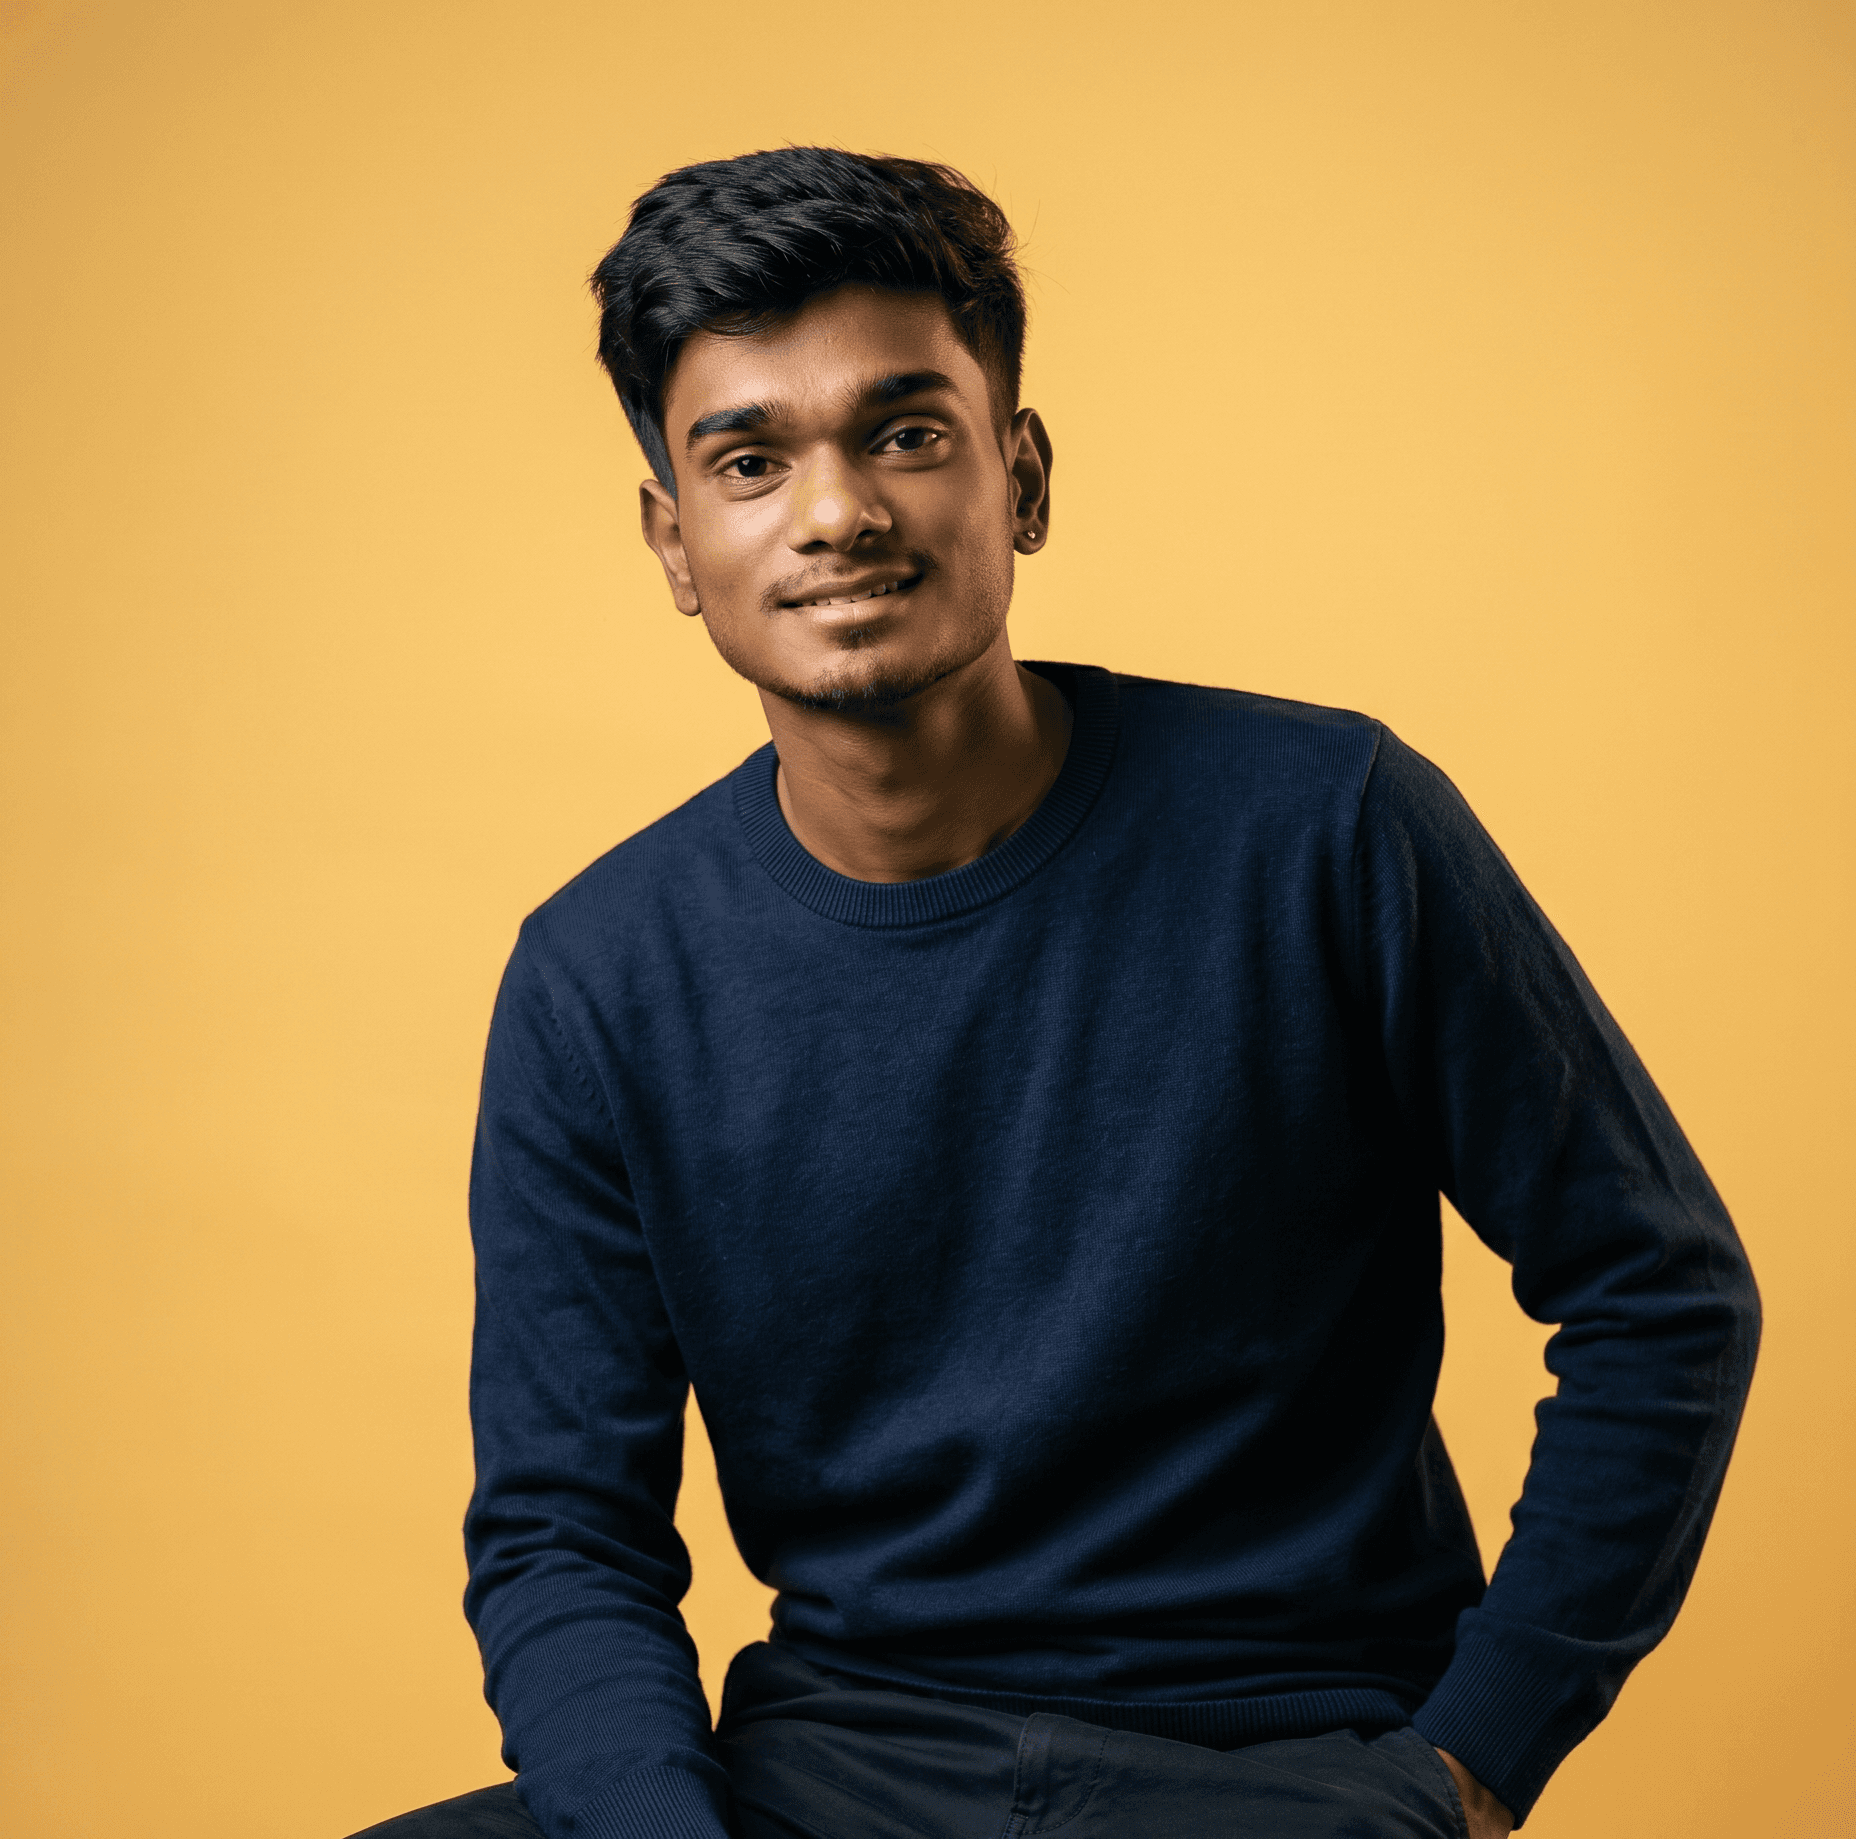
Focused on advancing Applied AI Engineering by developing intelligent, robust, and ethical AI systems. Combining expertise in LLM integration, robotic systems, and machine learning with a strong foundation in AI safety principles to build context-aware and reliable solutions. Driven to solve complex challenges across areas such as autonomous navigation, human-robot interaction, and safe AI deployment.
My MSc in Robotics and Mechatronics Engineering background, reinforced by an internship at Hyundai Motors, has given me a deep understanding of developing and optimising AI-driven robotic systems. From automating quality checks on assembly lines to managing operational workflows, I continually look for ways to boost efficiency and reliability through intelligent automation.
What truly sets me apart is my practical design and security experience in AI. My projects, like developing an adversarial attack and defence system for embodied AI and integrating large language models with robotic platforms, highlight my ability to build robust, safe, and intelligent AI solutions.
Now, I'm aiming for an opportunity to apply these skills in an Applied AI Engineer capacity. I'm keen to contribute to real-world AI applications, making a tangible impact on product development and operational effectiveness. Take a look at my portfolio for a deeper dive into how I turn complex challenges into well-designed AI solutions.
Focus Area
Responsible AI, Technical code, Vibe Code, Generative AI
Research
Embodied AI Safety, Multimodal model agents
Engineering
Multi-LLM Systems, Robotics
Building
AI + Robotics
USP
- Expertise in developing adversarial attack and defence frameworks for LLM-powered embodied agents, increasing AI safety and responsible deployment.
- Practical experience integrating large language models with robotic platforms to enable natural language understanding and intelligent decision-making.
- Professional background in automating quality validation for robotic production systems at Hyundai, driving operational excellence through data analysis.
- Skilled in building cloud-connected IoT architectures and data pipelines for real-time monitoring, relevant to scalable AI and machine learning integrations.
Profile Fit
LLM Attack & Defence Systems
Developing structured attack and defence frameworks across language model environments improved overall system robustness.
Applied Prompt Engineering
Applying targeted prompt engineering approaches improved both task execution performance and natural language understanding in AI systems.
Machine Learning for Autonomous Systems
Implementing algorithms like Kalman Filters and SLAM improved the accuracy and performance of autonomous navigation systems.
IoT System Architecture & Integration
Building end-to-end cloud-connected IoT architectures enabled real-time data monitoring and insightful analytics for environmental systems.
Skills & Expertise
Specialised across the AI and robotics stack from LLM safety to embedded integrate intellegence systems, with a focus on building responsible and powerful solutions
LLM Integration (Claude, Ollama, OpenAI)
Prompt Engineering & System Prompts
Multi-LLM Architectures
RAG Patterns
LLM Fine-Tuning (Hugging Face)
Featured Projects
Building real-world AI systems — from adversarial safety to embodied intelligence
AWS Hackathon • 2026
RescueAgent — Edinburgh Food Rescue
AWS Hackathon — Agentic Food Rescue Dispatch (Strands + Bedrock Qwen 3 235B)
Hackathon-built agentic system that rescues surplus food in Edinburgh. A kitchen types one sentence — the agent classifies against UK FSA thermal rules, matches the nearest eligible shelter by capacity/demand, broadcasts to the 3 nearest capable volunteer drivers, and tracks the live OSRM road route until handover. Strands Agents SDK on Amazon Bedrock Qwen 3 235B, Streamlit live map, 1,612 restaurants + 20 shelters + 40 drivers.
1,612 restaurants · 40 drivers · 90/240 min FSA windows · 60 fps live map
Heriot-Watt University • 2026
Warehouse Robot LLM — Dissertation Project
Local-First Hybrid VLM-SLM Exception Recovery Pipeline
MSc dissertation engineering an edge-first autonomous warehouse robot recovery pipeline. Five-stage architecture — Moondream2 VLM, privacy gateway, Qwen2.5-3B local reasoner, symbolic safety verifier, and Gemini Flash cloud fallback — evaluated on a 100-image warehouse corpus across four tracks.
100-image evaluation across 4 tracks · 5-stage local-first pipeline
Heriot-Watt University • 2025 – Present
Adversarial Safety in Embodied AI
LLM Attack & Defence System for Responsible AI
This project revolved around building secure and reliable AI systems, specifically addressing the safety of Large Language Models (LLMs) used within operating in varied environments. Focus was placed on understanding and mitigating potential vulnerabilities, directly relevant to the role of an Applied AI Engineer who needs to ensure AI system integrity.
Multi-LLM safety framework for regulated industries
Heriot-Watt University • 2025
CDPR Machine Vision Pipeline
YOLO-Based Pick & Place for Cable Robots
Real-time pick-and-place vision system for a 4-Cable Driven Parallel Robot using YOLO object detection, MJPEG IP camera streaming, and RS-232 serial control for full pick-and-place automation.
Real-time YOLO detection at 30 FPS with sub-second pick cycle
Heriot-Watt University • 2025
4-Cable Driven Parallel Robot
Simulation, Firmware & ROS 2 Control Stack
Complete software stack for a cable-driven parallel robot with 4 cables, including MuJoCo physics simulation, Arduino/OpenCR firmware with inverse kinematics and 6-DOF wrench solver, and ROS 2 nodes for IK and teleoperation.
6-DOF wrench solver at 100Hz on embedded hardware
GenAI Integration with Robotic Systems
Natural Language HRI with Vision Understanding
This work involved merging advanced language models with robotic platforms, allowing robots to understand and respond to natural language. For an Applied AI Engineer, this highlights an ability to bridge powerful AI models with practical hardware, resulting in intelligent robotic behaviours and improved human-robot interactions.
Real-time natural language robot control
Cloud-Connected IoT Data Pipeline
End-to-End Environment Monitoring System
Built a full-stack IoT solution from physical ESP32 sensors through ESP-NOW to MQTT messaging and Node-RED dashboard. Real-time temperature and humidity monitoring with bidirectional command relay and automated alerting.
24/7 monitoring with deep-sleep sensor nodes (<100µA idle)
Autonomous Navigation System
ROS 2 SLAM with Advanced Path Planning
This project focused on developing robust autonomous navigation capabilities for robotic platforms. This demonstrates essential skills for an Applied AI Engineer in developing decision-making algorithms and deploying them in real-world or simulated robotic systems.
Real-time SLAM at 10Hz with 95% localisation accuracy
Other Projects
Semi-Automatic Natural Waste Cleaner Rover
Autonomous Environmental Cleanup Robot
Analysis of Metal Matrix Composite with TiO2
Material Science Research & Testing
National Electric Bike Challenge
E-Vehicle Design & Competition
Previous Experiences
Hyundai Motors Pvt. Ltd. — Production Engineering Intern
Primary Responsibilities:
- Implemented automation strategies for quality validation within robotic production systems.
- Analysed operational data to inform process optimisation and identify efficiency.
- Prepared reports on manufacturing performance, including throughput and quality metrics.
- Maintained compliance in high-volume production while monitoring robotics-assisted manufacturing.
Specific Projects and Contributions:
- Automated quality validation for robotic production across multiple assembly lines.
- Performed data analysis on equipment and workflow to evaluate effectiveness.
- Contributed to defining process standardisation in support of operational excellence.
Contribution to Mission:
This role directly supported Hyundai Motors' objectives by enhancing manufacturing precision and efficiency through automation and data-informed decision-making, which helped maintain high production standards and comply with operational guidelines.
Skills Developed: Automation, Data Analysis, Process Optimisation, Report Generation, Quality Assurance, Robotics Monitoring, Workflow Analysis, Operational Compliance
Upwork — Startup Ecosystem Associate
Primary Responsibilities:
- Managed cross-functional communications, optimising workflows for client requests.
- Supported operational events, ensuring adherence to service protocols.
- Handled shift operations, balancing priorities and resolving client issues.
Specific Projects and Contributions:
- Optimised client request workflows, which reduced average response times during peak periods.
- Ensured 100% compliance with service protocols during operational events, while maintaining service quality for over 50 participants per event.
- Improved service accuracy scores by resolving complex client issues within the startup ecosystem.
Contribution to Mission:
This position supported Venture Cafe's mission by improving the efficiency and quality of client interactions and event operations, which contributed significantly to service delivery and ecosystem support.
Skills Developed: Workflow Optimisation, Cross-functional Communication, Event Support, Operations Management, Client Issue Resolution, Service Protocol Compliance
Education
MSc Robotics
Heriot-Watt University
Sep 2025 — Sep 2026
Heriot-Watt University, UK
- Specialising in autonomous systems, embodied AI, and human-robot interaction
- Research focus on integrating LLMs with robotic systems for intelligent decision-making
- Coursework in advanced robotics, computer vision, and machine learning
B.E Mechatronics Engineering
Kongu Engineering College
Aug 2021 — May 2025
Perundurai, India
- Graduated with 7.91 CGPA, specialising in robotics and AI integration
- Done projects in metallurgy, robot simulations(ABB, FANUC), CAD(AutoCAD, SolidWorks, Ansys)
- Bachelor's project related to Rover design of Prototyping and testing.
Leadership & Activities
Beyond the lab — leading teams, competing nationally, and giving back
The Robotics Society
Secretary
Lead a 30+ member team in the club by providing various events, speech, workshops and Webinars in related to Mechatronics and Robotics field in Centre of Excellence for 1 year.
Venture Cafe's Edinburgh
Ambassador Volunteer
Guided and volunteered at Venture Cafe's Edinburgh in hospitality, social media, marketing, and hosting.
AI Community Contributor
Hugging Face / Open Source
Active contributor to open-source AI safety tools and LLM evaluation benchmarks.
Let's Connect
Open to opportunities in AI Engineering, Research, and Robotics
Whether you're looking for an AI engineer, want to discuss research collaboration, or just want to chat about the future of embodied AI and robotics, feel free to reach out. I'd love to hear from you.
Send Me an EmailBlog & Insights
Build logs, hackathon breakdowns, and robotics notes — free, on your portfolio. Click any post to read inside.
2026-03-15 • 8 min
RescueAgent — Agentic Food Rescue for Edinburgh
AWS Hackathon build: one sentence from a kitchen manager → FSA-classified, shelter-matched, and dispatched to the 3 nearest capable drivers on a live 60 fps OSRM map. 7 tools, Strands + Bedrock Qwen 3 235B.
Read inside